KM Series
KM Series Multi-Axis Cartesian Systems (Cartesian Robot KK Series)
- Type
- Pre-configured multi-axis system (KK stages)
- Configurations
- 21 standard models, 8 frame types (T1 - T8)
- Axes
- 2 (XY, YZ, XZ) or 3 (XYZ)
- Payload
- 2 [kg] - 40 [kg]
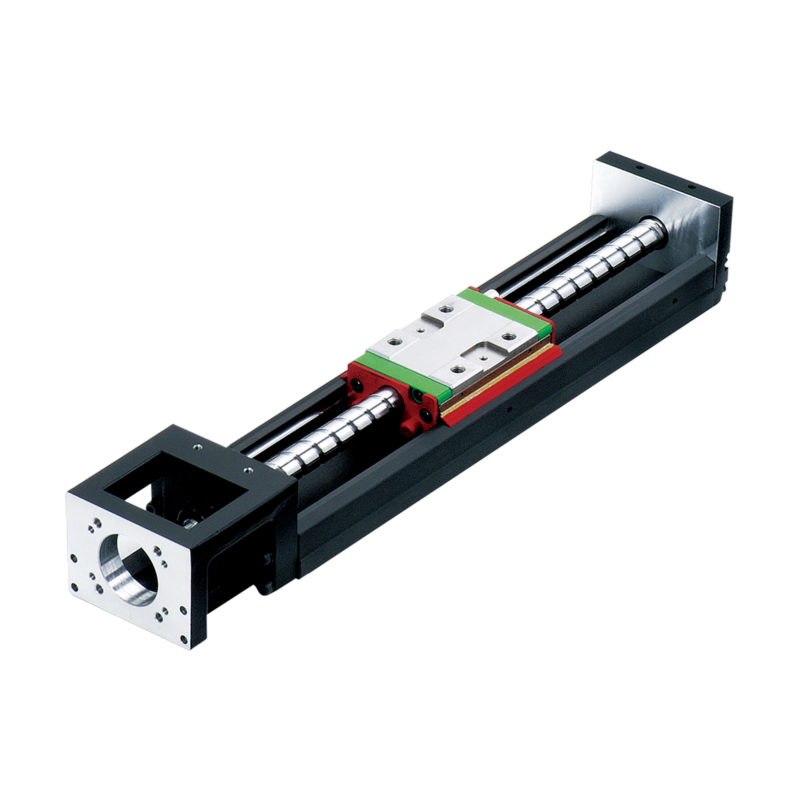
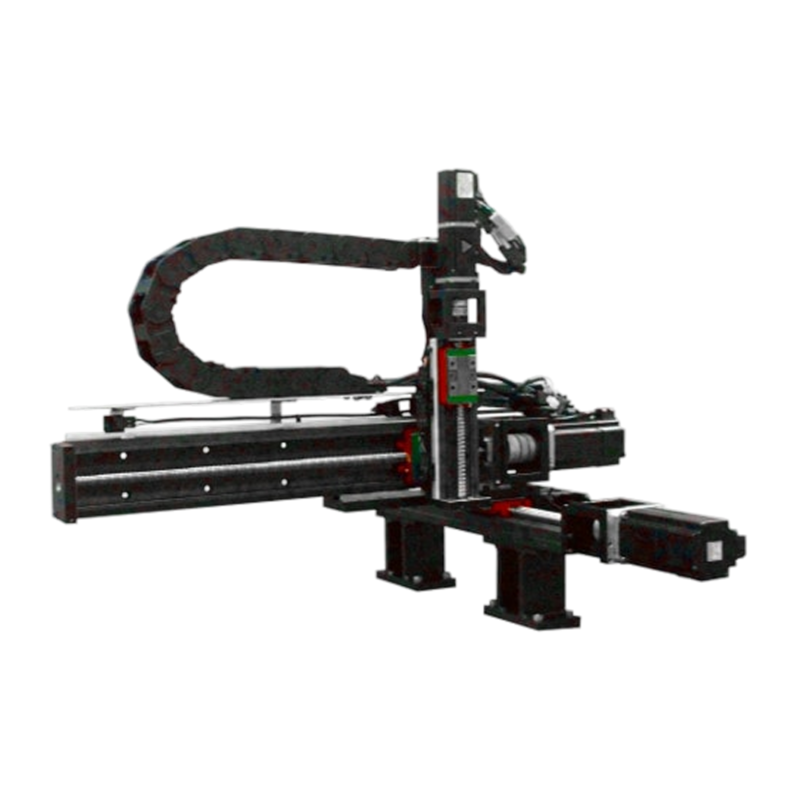
Hiwin's KM series is a pre-designed, and configurable, multi-axis system using Hiwin's premiere ballscrew driven KK stages. Configurations include cantilever (cartesian), XY cross table, single driven and dual driven gantry. Hiwin provides additional value through time savings for designing, sourcing, and machining with pre-made brackets and configurations allowing you to focus your resources on the process rather than the motion products. The KM systems can be sold as assemblies or kits including brackets with additional items such as motors, cables, cable chains, servo drives, and couplings.
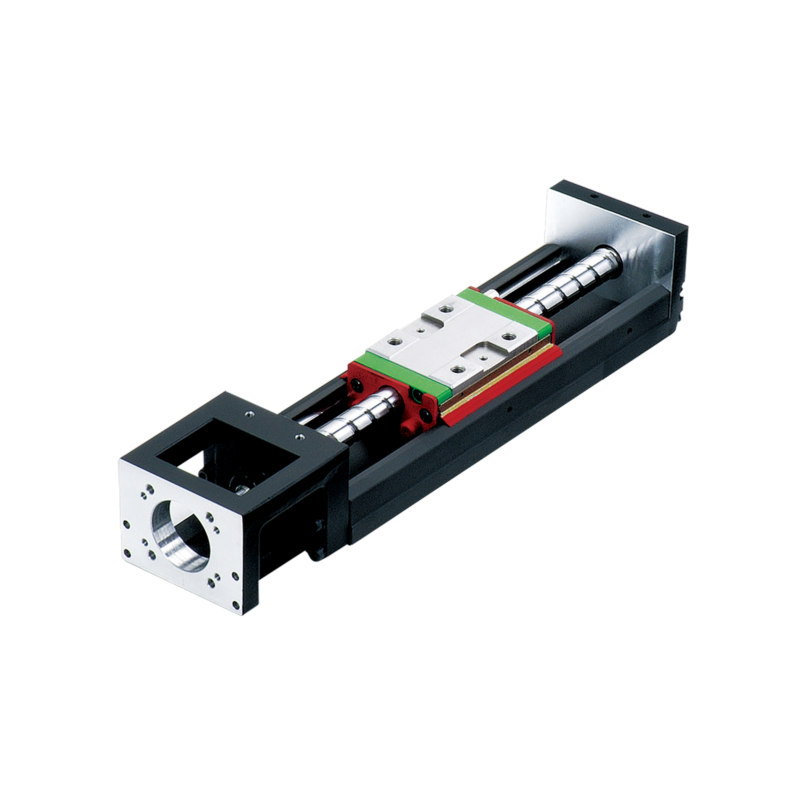
KM systems are configured from KK stages; for a single axis, start from the KK itself. View KK Series →
-
21
Standard configurations in the catalog, across 8 frame types
-
±0.005 mm
Repeatability per axis on KK50 to KK86 stages (±0.01 mm on KK100)
-
40 kg
Max payload (HRCR-KK1086XX-T1 cantilever, shortest stroke)
Applications
- Screw fastening
- Dispensing
- Loading and unloading
- Material transfer
- Assembly
- Welding
- Packaging
- Inspection
- Cutting
Configurations
The model code strings the X, Y and Z stage sizes ahead of the frame type: 10 = KK100, 86 = KK86, 60 = KK60, 50 = KK50, and XX marks an axis the configuration does not use. Where the payload column shows a range, it is the catalog's max load capacity from the longest standard stroke to the shortest; single values hold across all standard strokes.
| Model number | Type | Axes | Axis stages | Max. payload (kg) | Configure |
|---|---|---|---|---|---|
| HRCR-KK8660XX-T1 | Cantilever | 2 / XY | X KK86D · Y KK60D | 10–25 | Configure ↗ |
| HRCR-KK1086XX-T1 | Cantilever | 2 / XY | X KK100 · Y KK86D | 12–40 | Configure ↗ |
| HRCR-KK8660XX-T2 | Cross (horizontal) | 2 / XY | X KK86D · Y KK60D | 10–25 | Configure ↗ |
| HRCR-KKXX8660-T2 | Cross (wall-mounted) | 2 / YZ | Y KK86D · Z KK60D | 15 | Configure ↗ |
| HRCR-KK1086XX-T2 | Cross (horizontal) | 2 / XY | X KK100 · Y KK86D | 9–35 | Configure ↗ |
| HRCR-KKXX1086-T2 | Cross (wall-mounted) | 2 / YZ | Y KK100 · Z KK86D | 30 | Configure ↗ |
| HRCR-KK8660XX-T3 | Moving arm (horizontal) | 2 / XY | X KK86D · Y KK60D | 2–11 | Configure ↗ |
| HRCR-KKXX8660-T3 | Moving arm (wall-mounted) | 2 / YZ | Y KK86D · Z KK60D | 9–12 | Configure ↗ |
| HRCR-KKXX6086-T3 | Moving arm (vertical) | 2 / ZY | Y KK60D · Z KK86D | 9–13 | Configure ↗ |
| HRCR-KK1086XX-T3 | Moving arm (horizontal) | 2 / XY | X KK100 · Y KK86D | 7–25 | Configure ↗ |
| HRCR-KKXX1086-T3 | Moving arm (wall-mounted) | 2 / YZ | Y KK100 · Z KK86D | 21–25 | Configure ↗ |
| HRCR-KKXX8610-T3 | Moving arm (vertical) | 2 / ZY | Y KK86D · Z KK100 | 10–17 | Configure ↗ |
| HRCR-KK86XX60-T4 | Polar | 2 / XZ | X KK86D · Z KK60D | 10 | Configure ↗ |
| HRCR-KK10XX86-T4 | Polar | 2 / XZ | X KK100 · Z KK86D | 28 | Configure ↗ |
| HRCR-KK8660XX-T5 | Gantry | 2 / XY | X KK86D + KK86D auxiliary · Y KK60D | 20 | Configure ↗ |
| HRCR-KK1086XX-T5 | Gantry | 2 / XY | X KK100 + KK100 auxiliary (gantry control) · Y KK86D | 24–32 | Configure ↗ |
| HRCR-KK866050-T6 | Cantilever | 3 / XYZ | X KK86D · Y KK60D · Z KK50 | 6.5 | Configure ↗ |
| HRCR-KK108660-T6 | Cantilever | 3 / XYZ | X KK100 · Y KK86D · Z KK60D | 10 | Configure ↗ |
| HRCR-KK866050-T7 | Gantry | 3 / XYZ | X KK86D + KK86D auxiliary · Y KK60D · Z KK50 | 6.5 | Configure ↗ |
| HRCR-KK108660-T7 | Gantry | 3 / XYZ | X KK100 + KK100 auxiliary (gantry control) · Y KK86D · Z KK60D | 11 | Configure ↗ |
| HRCR-KK106086-T8 | Polar | 3 / XYZ | X KK100 · Y KK60D · Z KK86D | 9–13 | Configure ↗ |
Part numbers & options
How a part number reads
HRCR - KK 10 86 60 - T1 1 S - X - Y - Z - E1 - S (spaces between decoded positions)
- HRCR
- Series — HIWIN Robot Cartesian Robot
- KK
- Mechanism — K KK single-axis stage series
- 10
- X axis size — 10 KK100 · 86 KK86 · 60 KK60 · 50 KK50 · XX unspecified
- 86
- Y axis size — 10 KK100 · 86 KK86 · 60 KK60 · 50 KK50 · XX unspecified
- 60
- Z axis size — 10 KK100 · 86 KK86 · 60 KK60 · 50 KK50 · XX unspecified
- T1
- Type — T1/T6 cantilever · T2 cross · T3 moving arm · T4/T8 polar · T5/T7 gantry
- 1
- Assembly orientation — per the assembly orientation diagram
- S
- Cover and mounting — S KK aluminum cover, mounted from top of rail · B KK labyrinth cover, mounted from bottom of rail
- X
- X axis effective stroke
- Y
- Y axis effective stroke
- Z
- Z axis effective stroke
- E1
- Servo motor — 0 not included · C provided by customer · E1 HIWIN MIKRO E1 series · HCR4 HCR4 controller
- S
- Shipping method — S assembled shipping · K KIT shipping (unassembled)
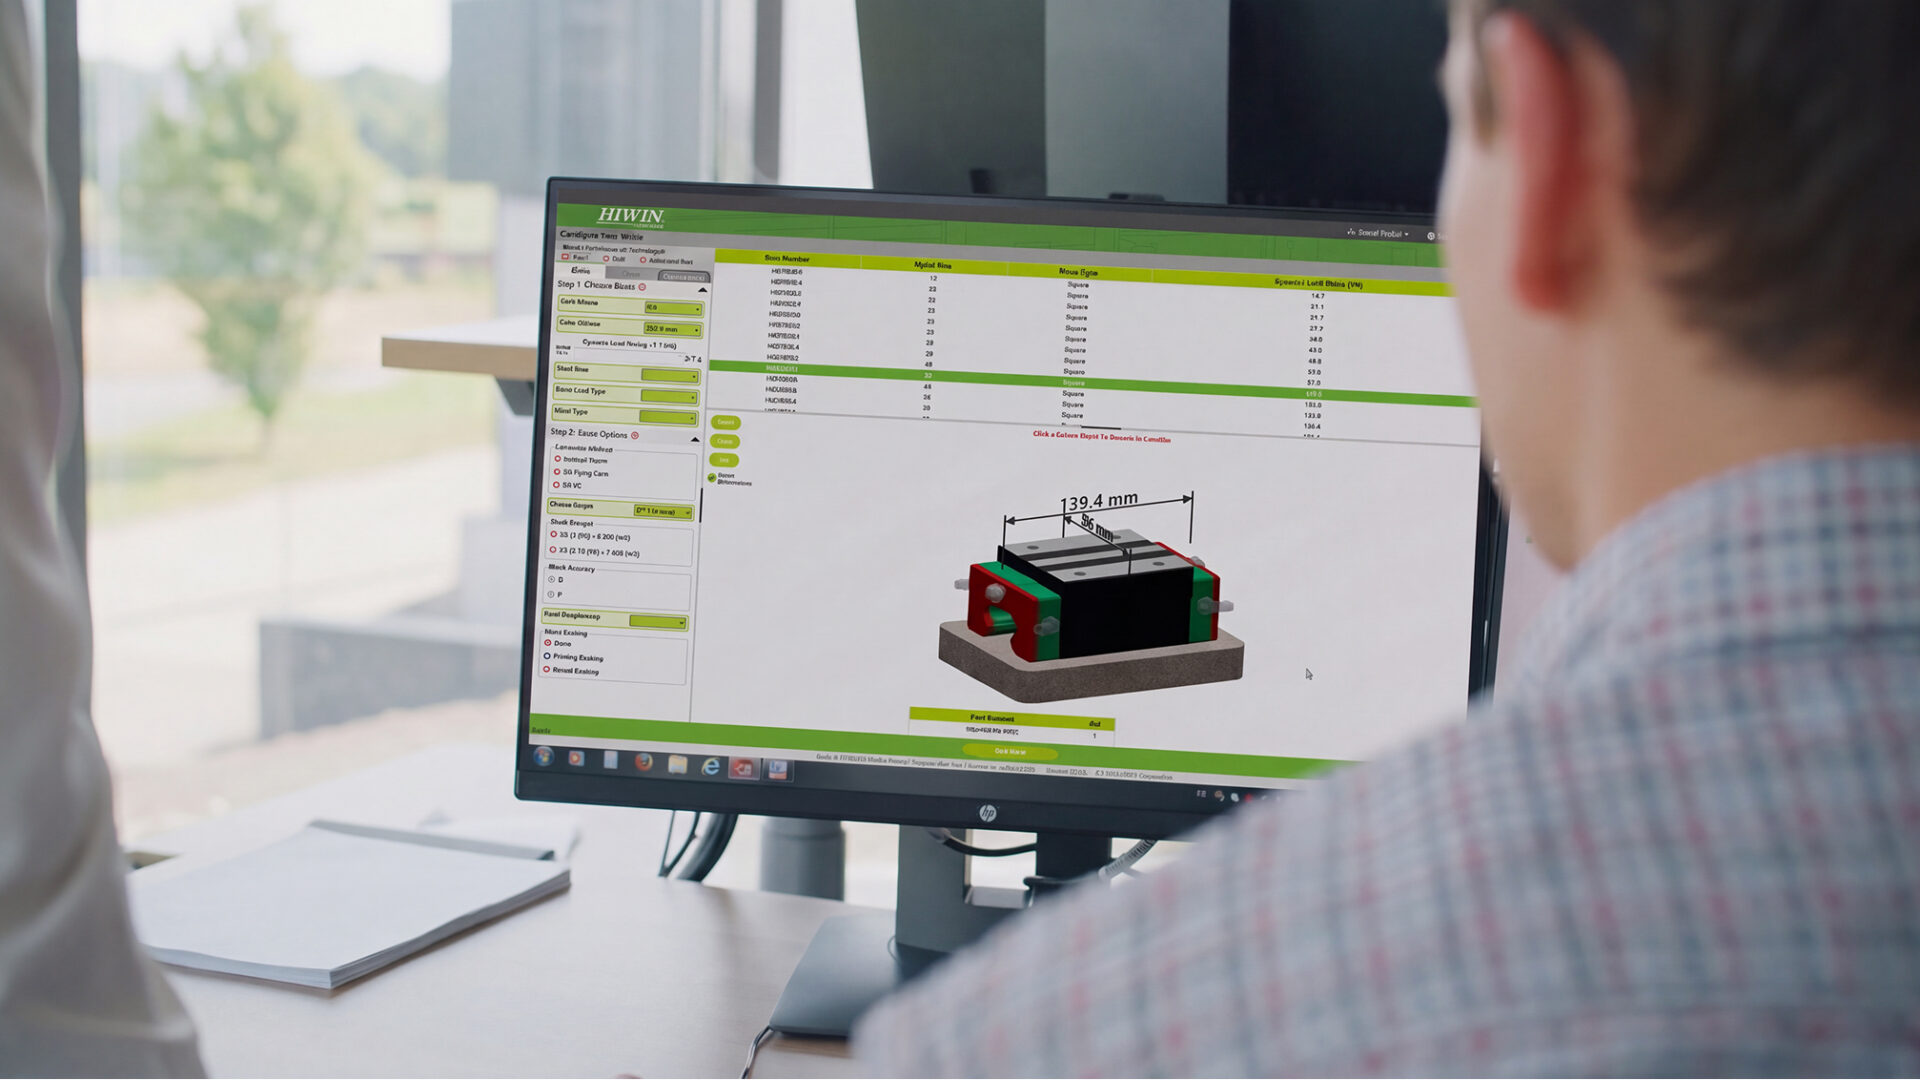
The configurator assembles this number for you, with drawings and 3D CAD. Configure ↗
Servo motor and controller
The motor slot orders the drive package shipped with the mechanism.
- 0 Not included — Mechanism only
- C Provided by customer — Mounts a customer-supplied servo
- E1 HIWIN MIKRO E1 series — AC servo motor and drive
- HCR4 HCR4 controller — Four-axis controller for the HCROS/HRSim stack
Cover and mounting
The cover code also sets the mounting direction of the KK stage.
- S KK aluminum cover — Mounting from the top of the rail
- B KK labyrinth cover — Mounting from the bottom of the rail
Shipping method
Systems ship built or as a kit.
- S Assembled shipping — Arrives as a working assembly
- K KIT shipping — Unassembled kit with brackets
How buying works
Spec it in the configurator: drawings, 3D CAD, and a quote to follow.
HIWIN series are configured to your application, not bought off the shelf. Start from your loads and speeds if you are still choosing a size.
Rather talk it through? Request a quote from an application engineer.